研究
以人为本的空间与智能系统研究
我的研究关注人们如何体验空间与智能系统,结合混合现实与 AR 原型、受控感知实验和参与式工作坊。研究主要在 KwanMyung Kim 教授的指导下,于 UNIST 的 IID 实验室(Integration and Innovation Design Lab)完成。
精彩亮点。
-
UNIST 硕士,2026 年 2 月。加入 IID 实验室两年后,获得工程设计硕士学位。
-
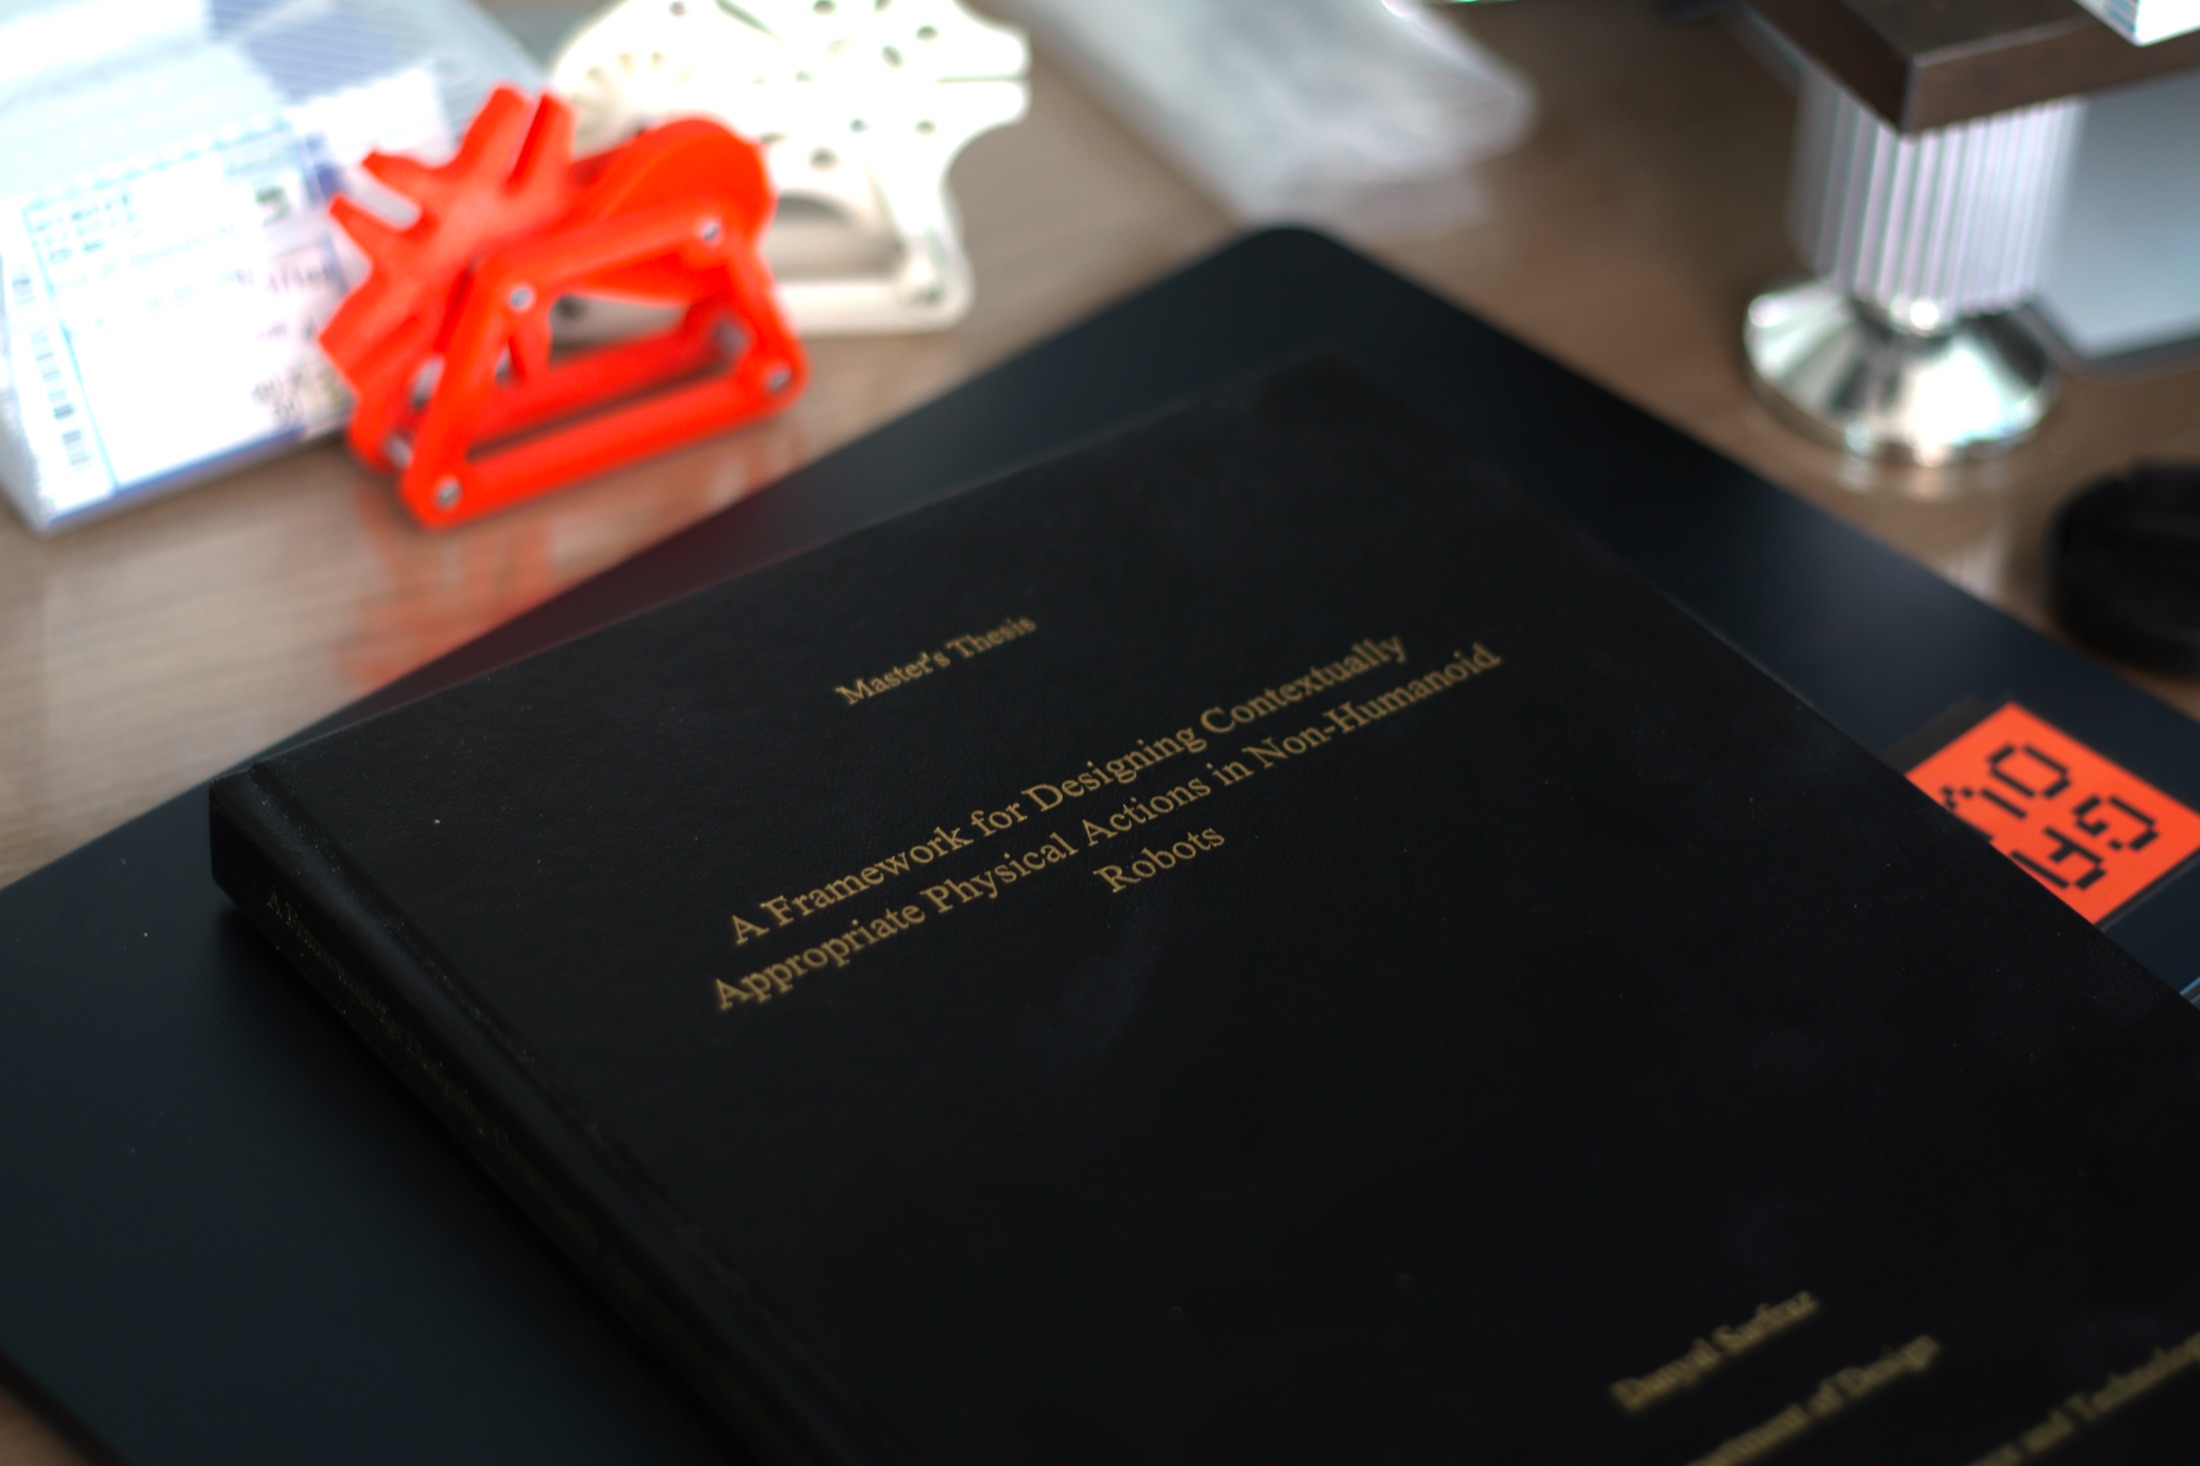
论文答辩,2025 年 12 月。一个用于设计机器人身体动作的框架。基于它的一篇论文正在 ACM CHI 2027 审稿中。
-
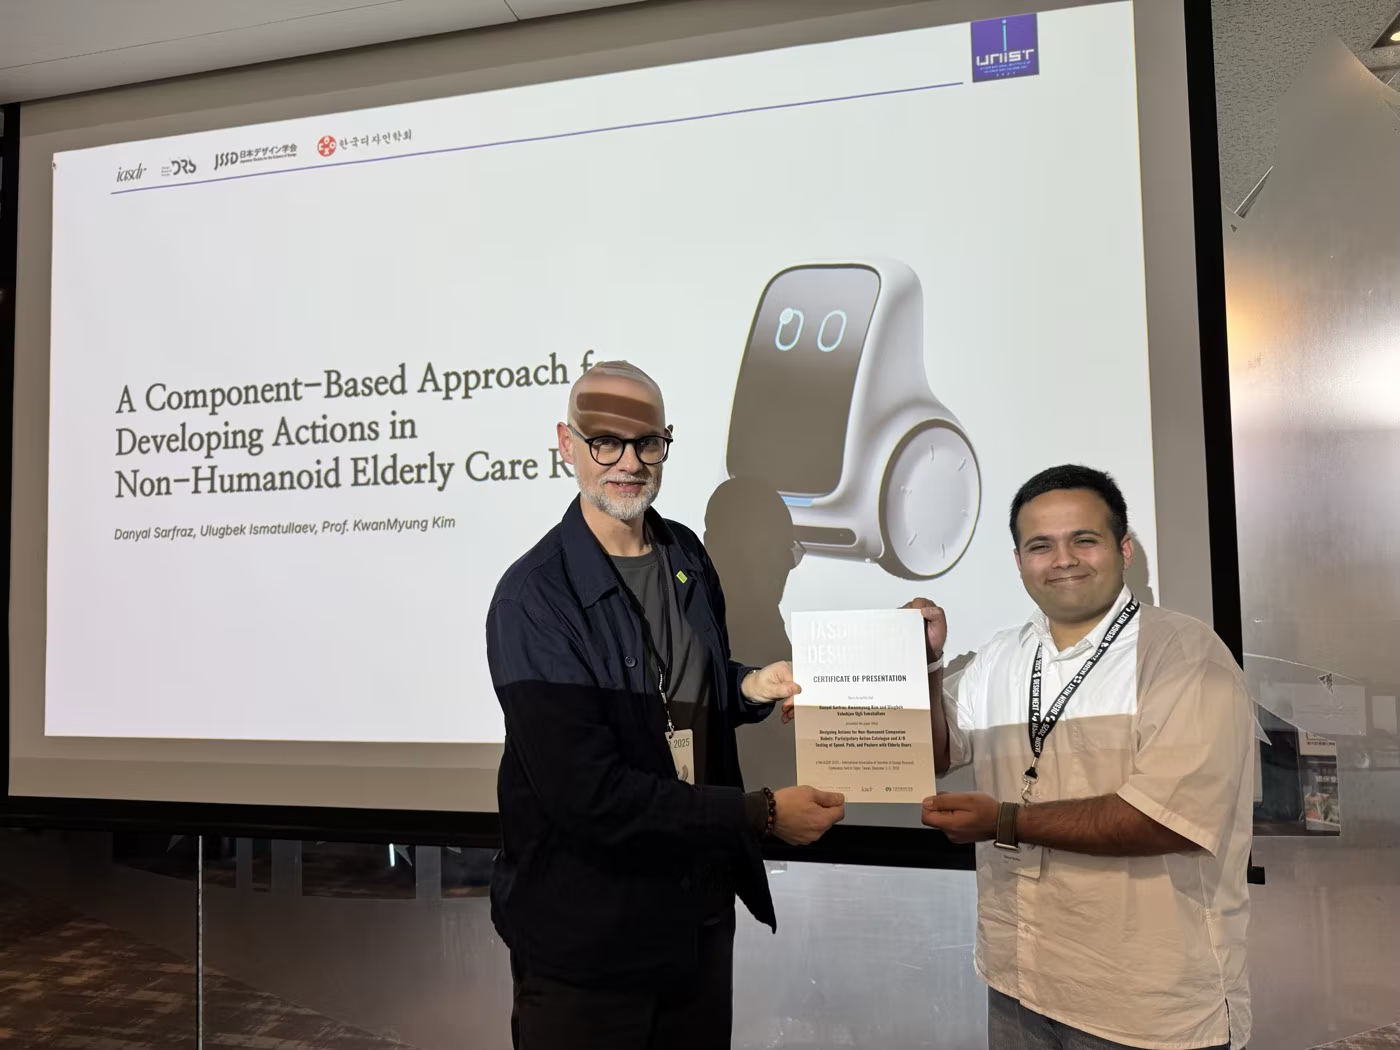
IASDR 2025,台北。一篇关于机器人动作的全文论文、一篇关于 AI 生成视频的图文论文,以及在海报环节与 Don Norman 的交流。
-
Lemmy 亮相,2025。在 CES 2025 上演示并获得创新奖,并在光州设计双年展展出。
-
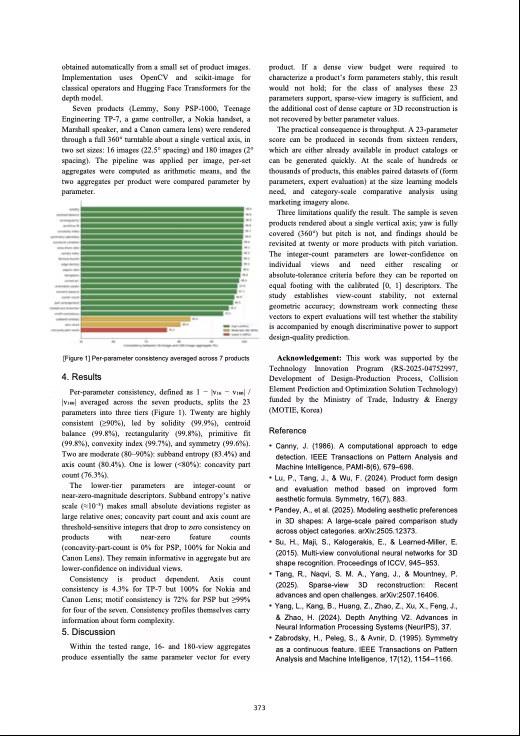
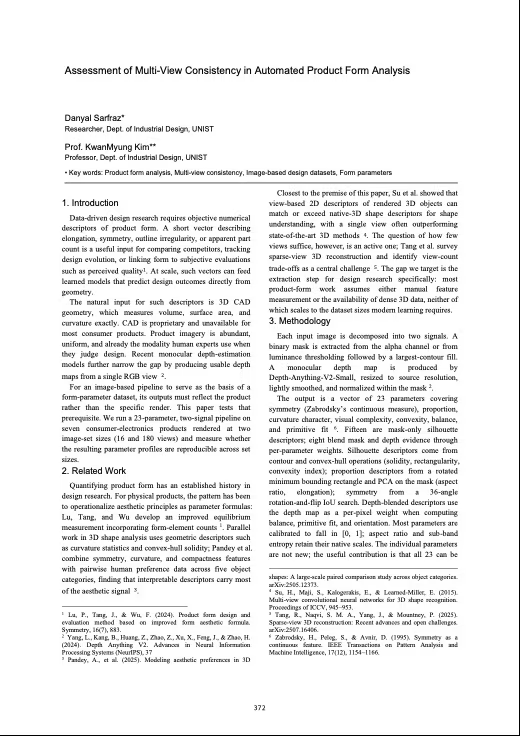
Assessment of Multi-View Consistency in Automated Product Form Analysis
查看详情: Product form analysis阅读论文@inproceedings{sarfraz2026multiview, author = {Sarfraz, Danyal and Kim, KwanMyung}, title = {Assessment of Multi-View Consistency in Automated Product Form Analysis}, booktitle = {Proceedings of the KSDS 2026 International Conference}, organization = {Korean Society of Design Science}, year = {2026} } -
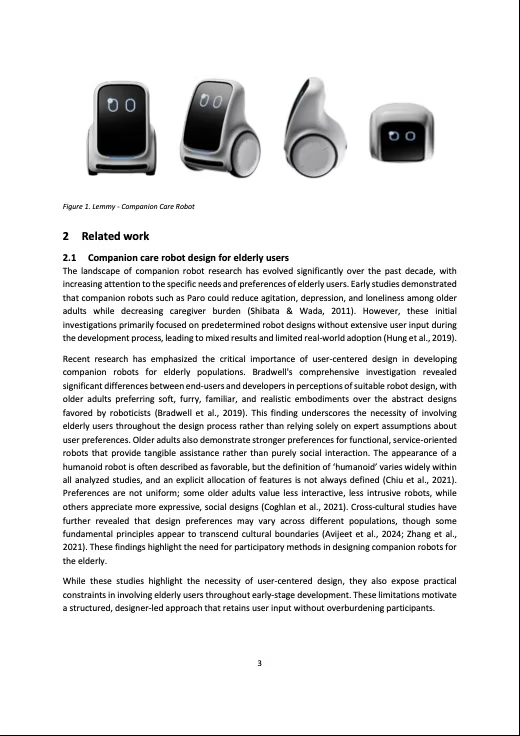
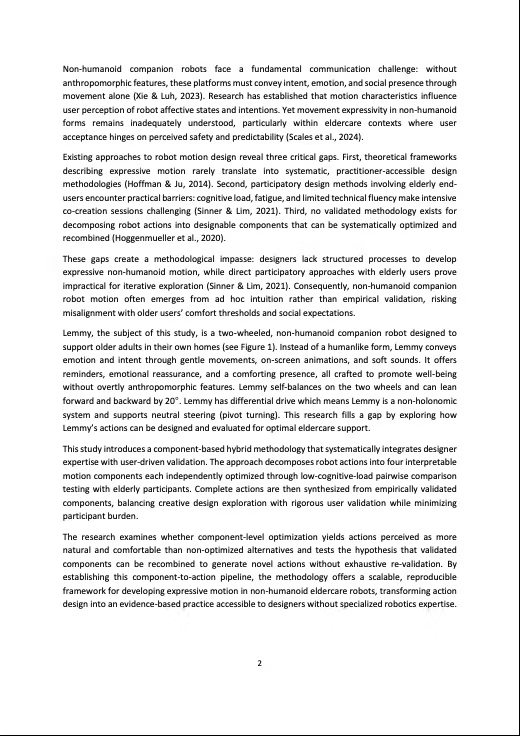
A Component-Based Approach for Developing Actions in Non-Humanoid Elderly Care Robots
查看详情: Lemmy阅读论文@inproceedings{sarfraz2025component, author = {Sarfraz, Danyal and Ismatullaev, Ulugbek Vahobjon Ugli and Kim, KwanMyung}, title = {A Component-Based Approach for Developing Actions in Non-Humanoid Elderly Care Robots}, booktitle = {IASDR 2025: Design Next}, address = {Taipei, Taiwan}, publisher = {Design Research Society}, year = {2025}, doi = {10.21606/iasdr.2025.1139} } -
Synthetic Realities: Evaluating Human Ability to Distinguish AI-Generated Videos from Real Footage
查看详情: Synthetic Realities阅读论文@inproceedings{sarfraz2025synthetic, author = {Sarfraz, Danyal and Karim, Raja Mubashar and Kim, KwanMyung}, title = {Synthetic Realities: Evaluating Human Ability to Distinguish AI-Generated Videos from Real Footage}, booktitle = {IASDR 2025: Design Next}, address = {Taipei, Taiwan}, publisher = {Design Research Society}, year = {2025}, doi = {10.21606/iasdr.2025.1050} } -
Developing a Hierarchically Structured Action Catalogue for an Elderly Care Robot through Participatory Design
查看详情: Lemmy阅读论文@inproceedings{sarfraz2025catalogue, author = {Sarfraz, Danyal and Ismatullaev, Ulugbek and Kim, KwanMyung}, title = {Developing a Hierarchically Structured Action Catalogue for an Elderly Care Robot through Participatory Design}, booktitle = {Proceedings of the KSDS 2025 International Conference}, organization = {Korean Society of Design Science}, pages = {166--167}, year = {2025} }
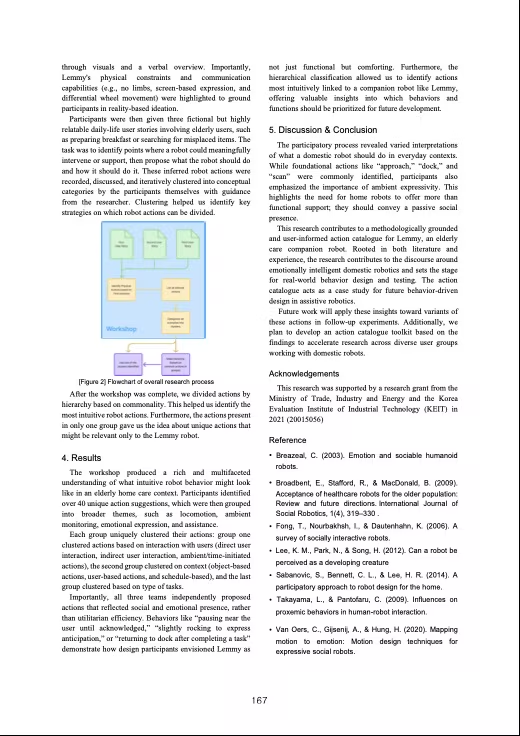
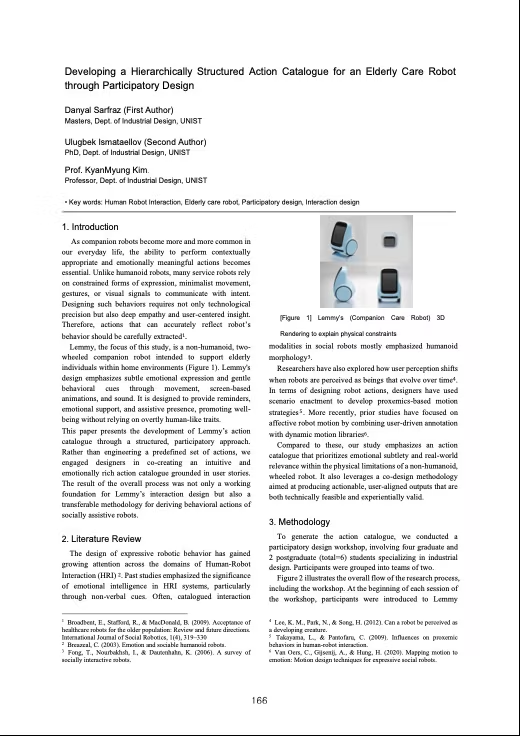
A Framework for Designing Contextually Appropriate Physical Actions in Non-Humanoid Robots. Danyal Sarfraz · 导师:KwanMyung Kim 教授. 基于该论文的一篇论文正在 ACM CHI 2027 审稿中。 查看详情: MSc thesis
@mastersthesis{sarfraz2026framework,
  author = {Sarfraz, Danyal},
  title  = {A Framework for Designing Contextually Appropriate Physical Actions in Non-Humanoid Robots},
  school = {Ulsan National Institute of Science and Technology},
  type   = {{MSc} thesis},
  year   = {2026}
}
产业研究项目
自 2024 年 2 月起,在 UNIST IID 实验室与产业界和政府合作伙伴共同开展的资助项目。
-
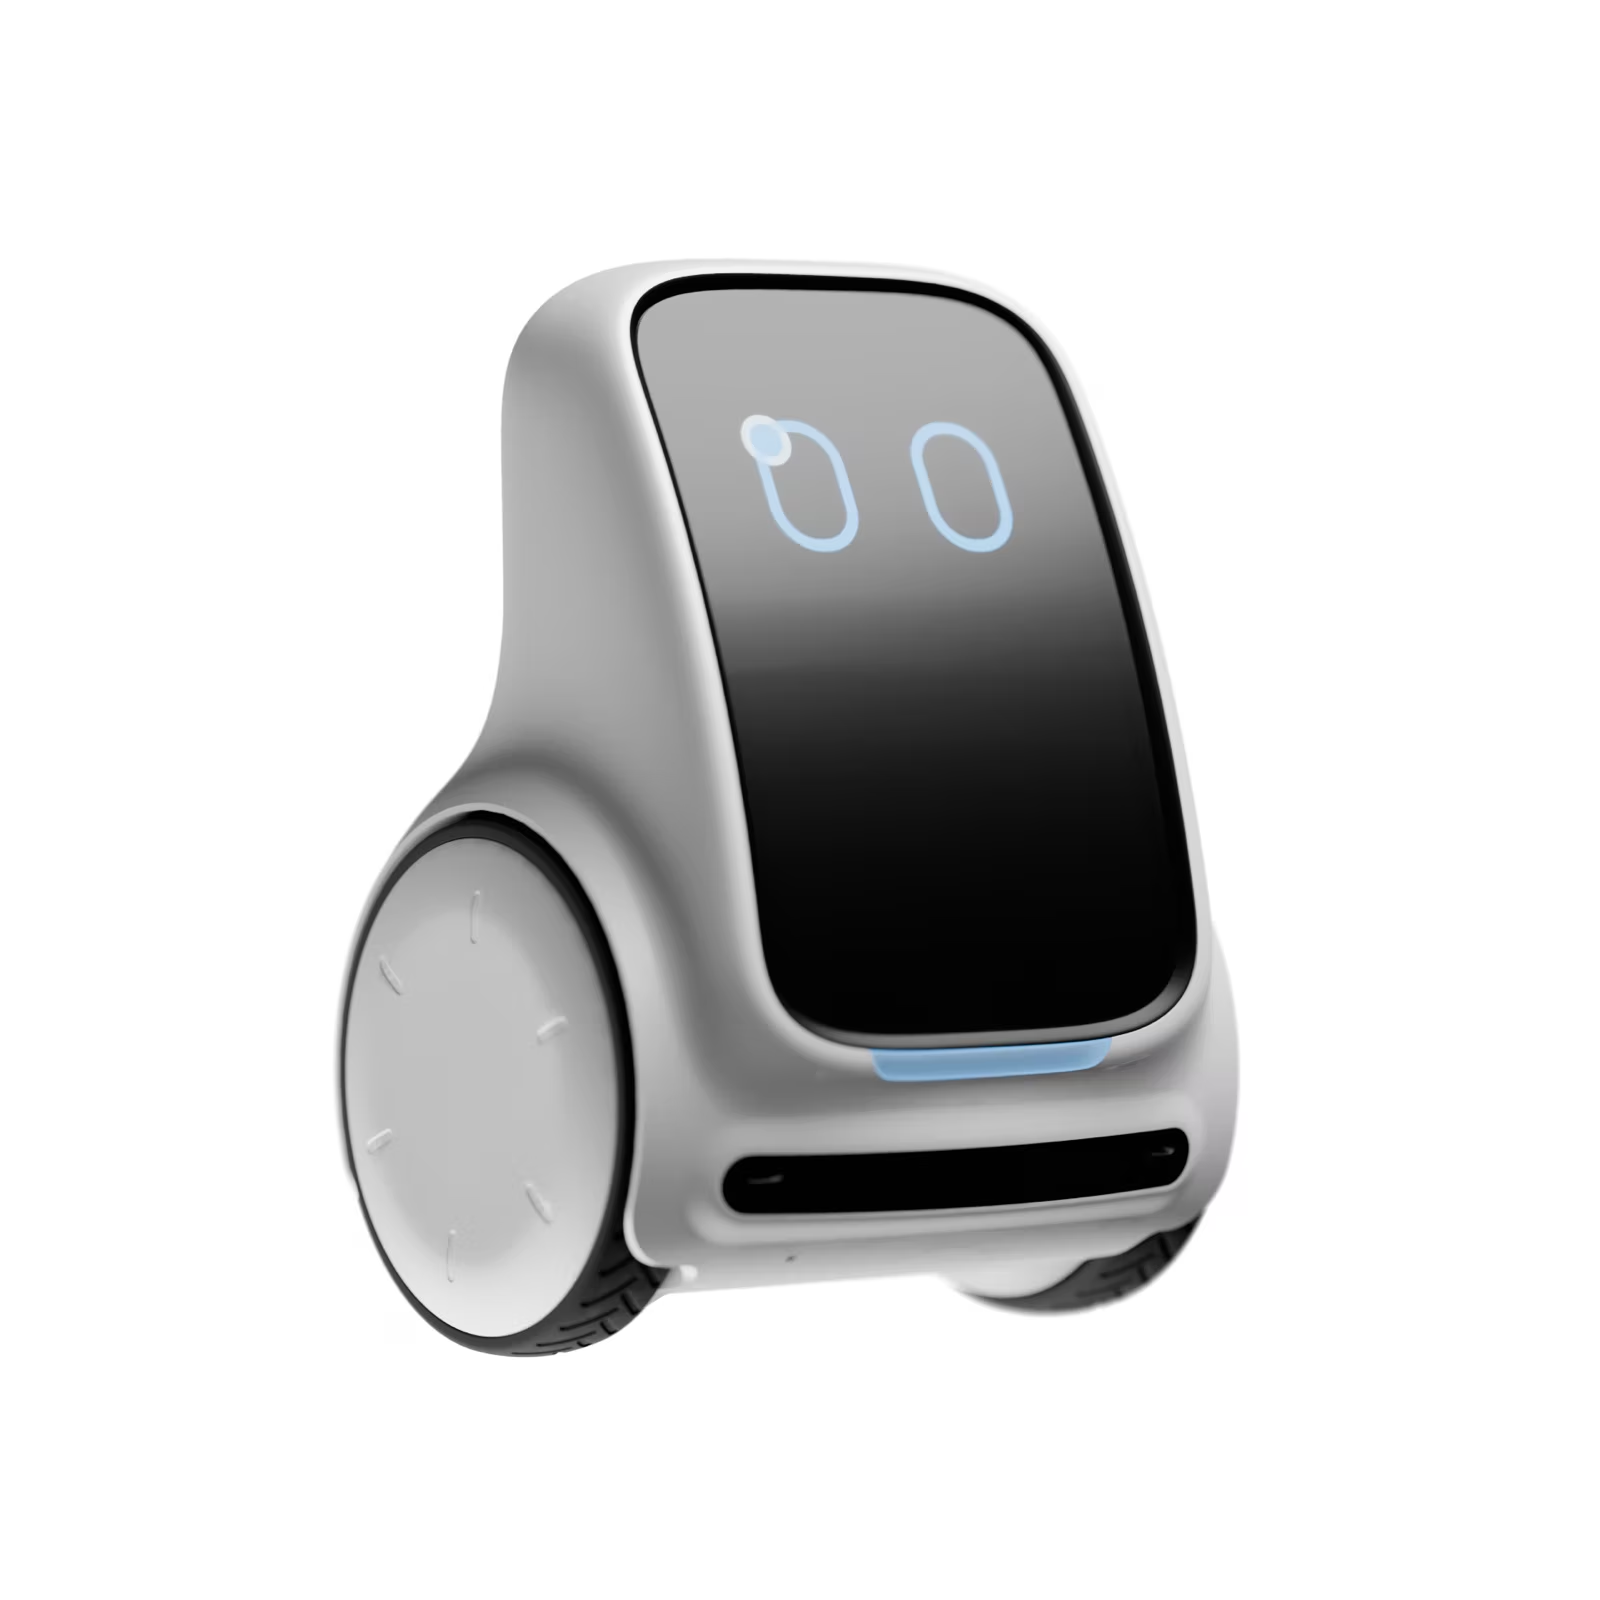
2024 – 2026 · 合作方:Shinsung Delta Tech
面向老年人的智能定制化照护产品服务系统
-

2025 年至今 · 合作方:Intensive、高丽大学
设计与生产冲突因素的预测与优化
-
2024 – 2026 · 合作方:韩国陆军
军民技术合作:战力支援体系开发
我负责:背包设计、重量分布和人体工学。
-
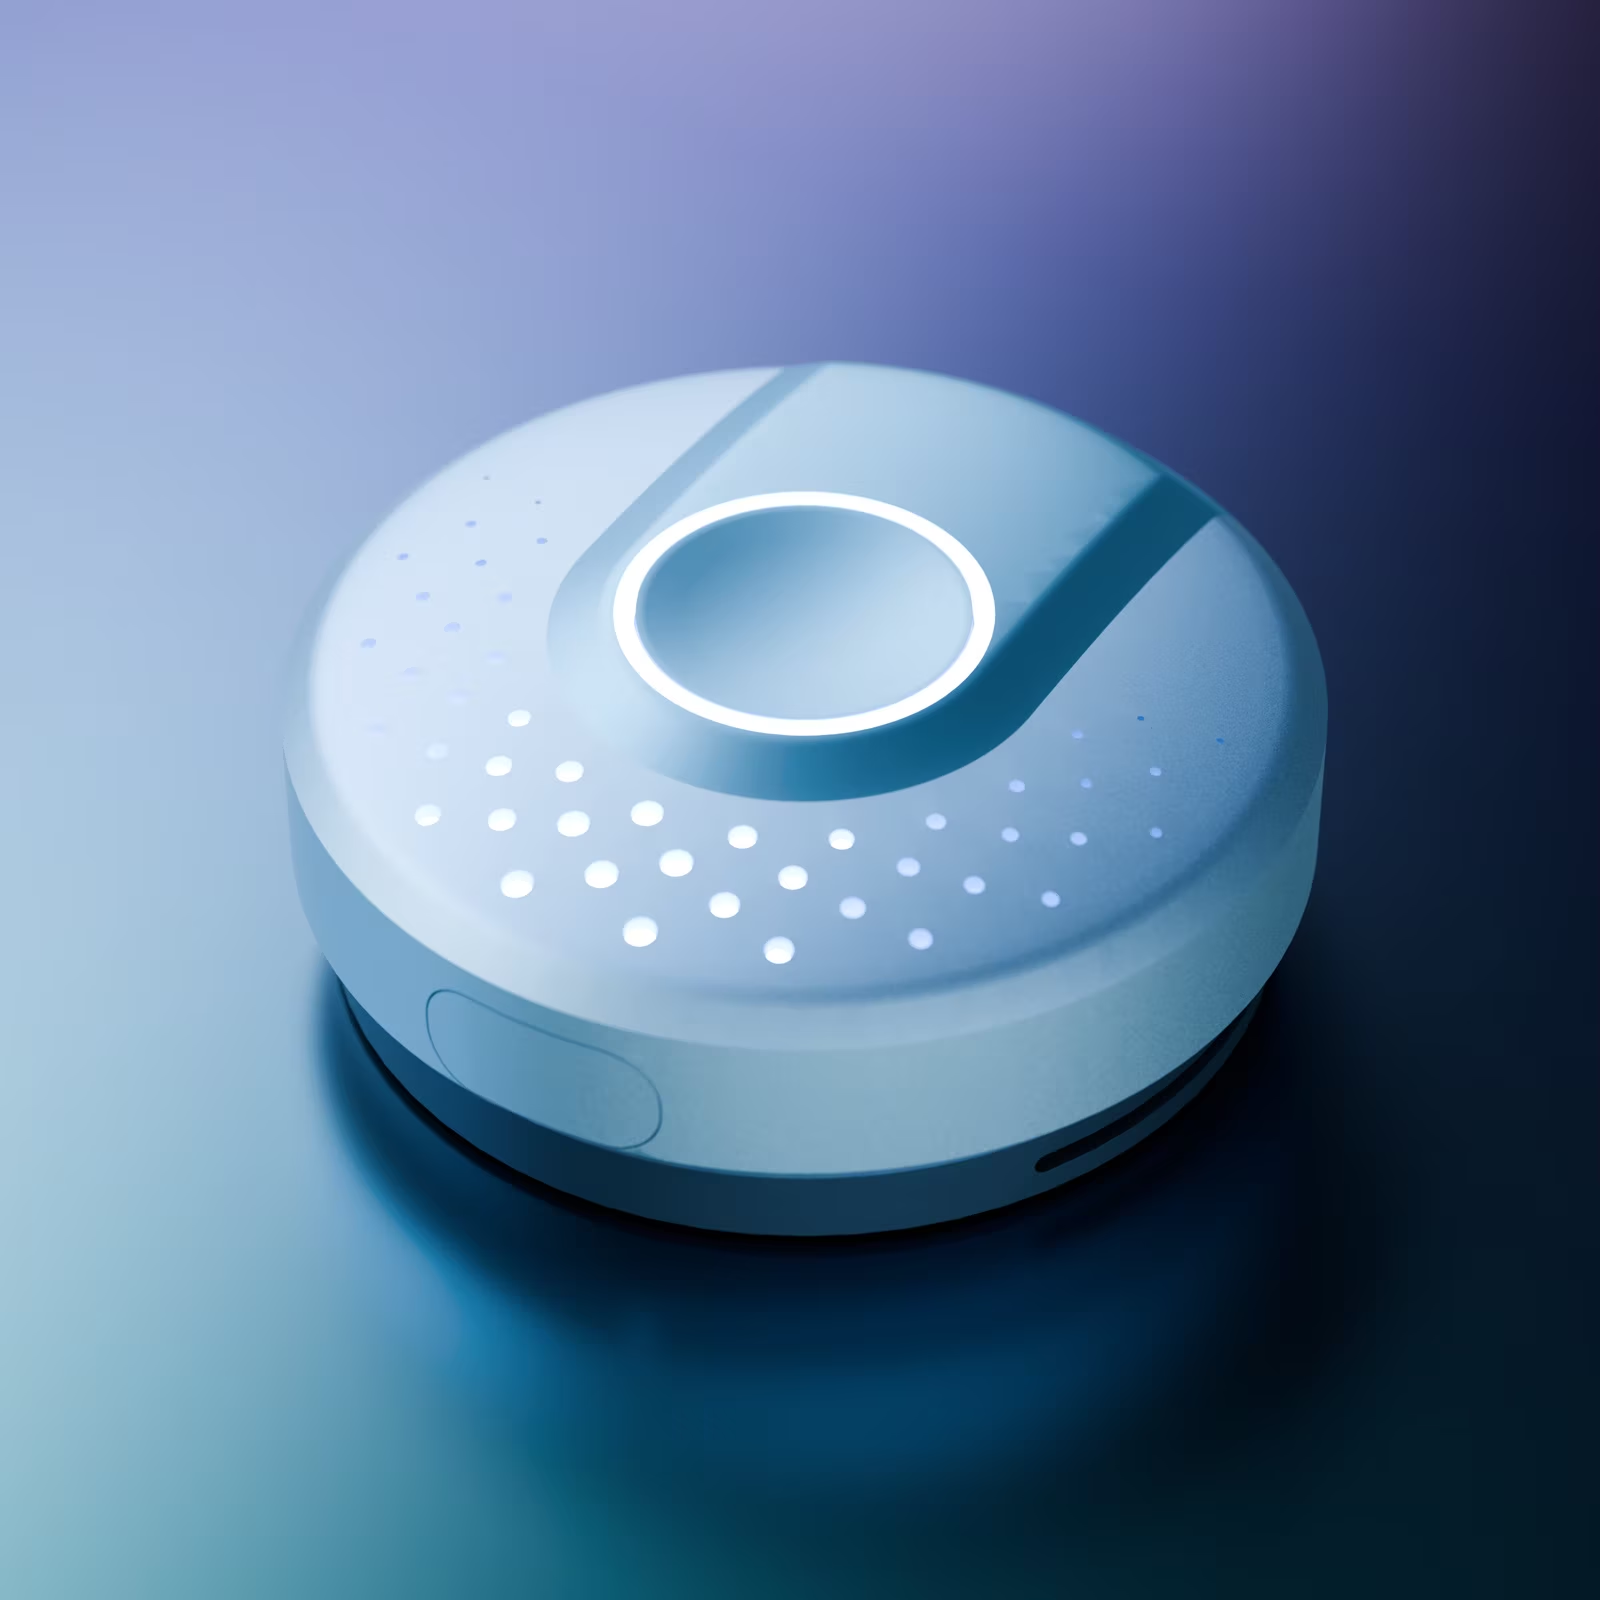
2024 · 合作方:LG Electronics
监测上半身角度与速度的传感器模块
获奖个人项目
第三届韩国文化遗产数字内容大赛 XR 类第一名。
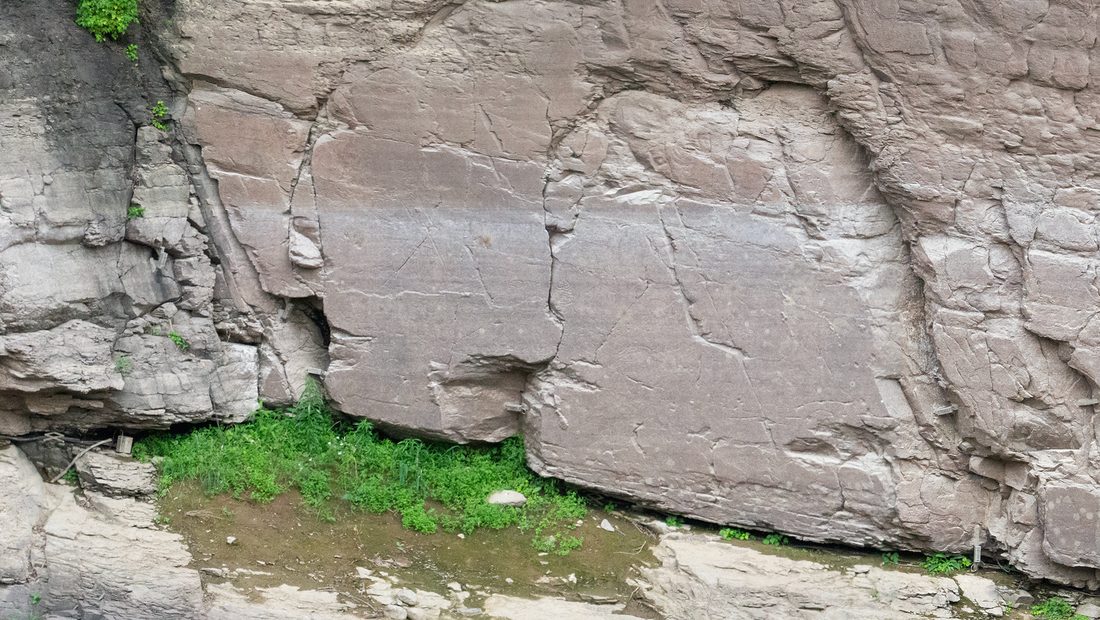
个人项目
针对人机交互经典问题的三项专题研究。
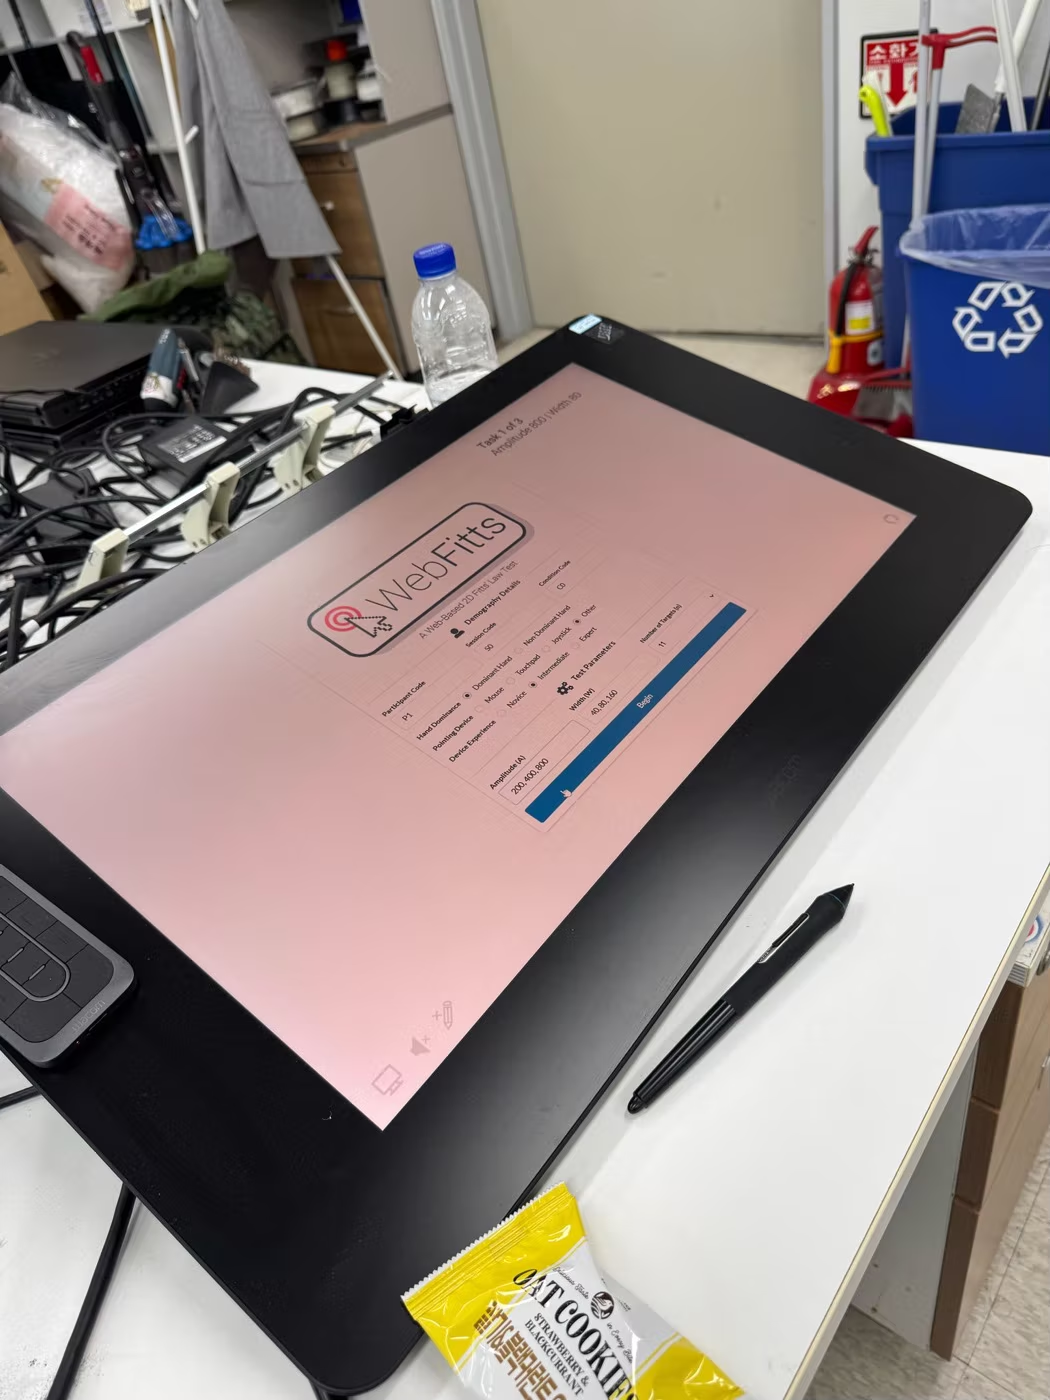
这些项目需要的工具当时还不存在,于是我自己做了出来。 查看工具