연구
공간 시스템과 지능형 시스템을 위한 인간 중심 연구
사람들이 공간 시스템과 지능형 시스템을 어떻게 경험하는지 연구합니다. 혼합 현실과 AR 프로토타입, 통제된 지각 실험, 참여형 워크숍을 결합해 접근합니다. 연구는 주로 UNIST Integration and Innovation Design Lab(IID Lab)에서 KwanMyung Kim 교수의 지도 아래 진행했습니다.
하이라이트 보기.
-
UNIST 석사, 2026년 2월. IID Lab에 합류한 지 2년 만에 엔지니어링 디자인 석사 과정을 마쳤습니다.
-
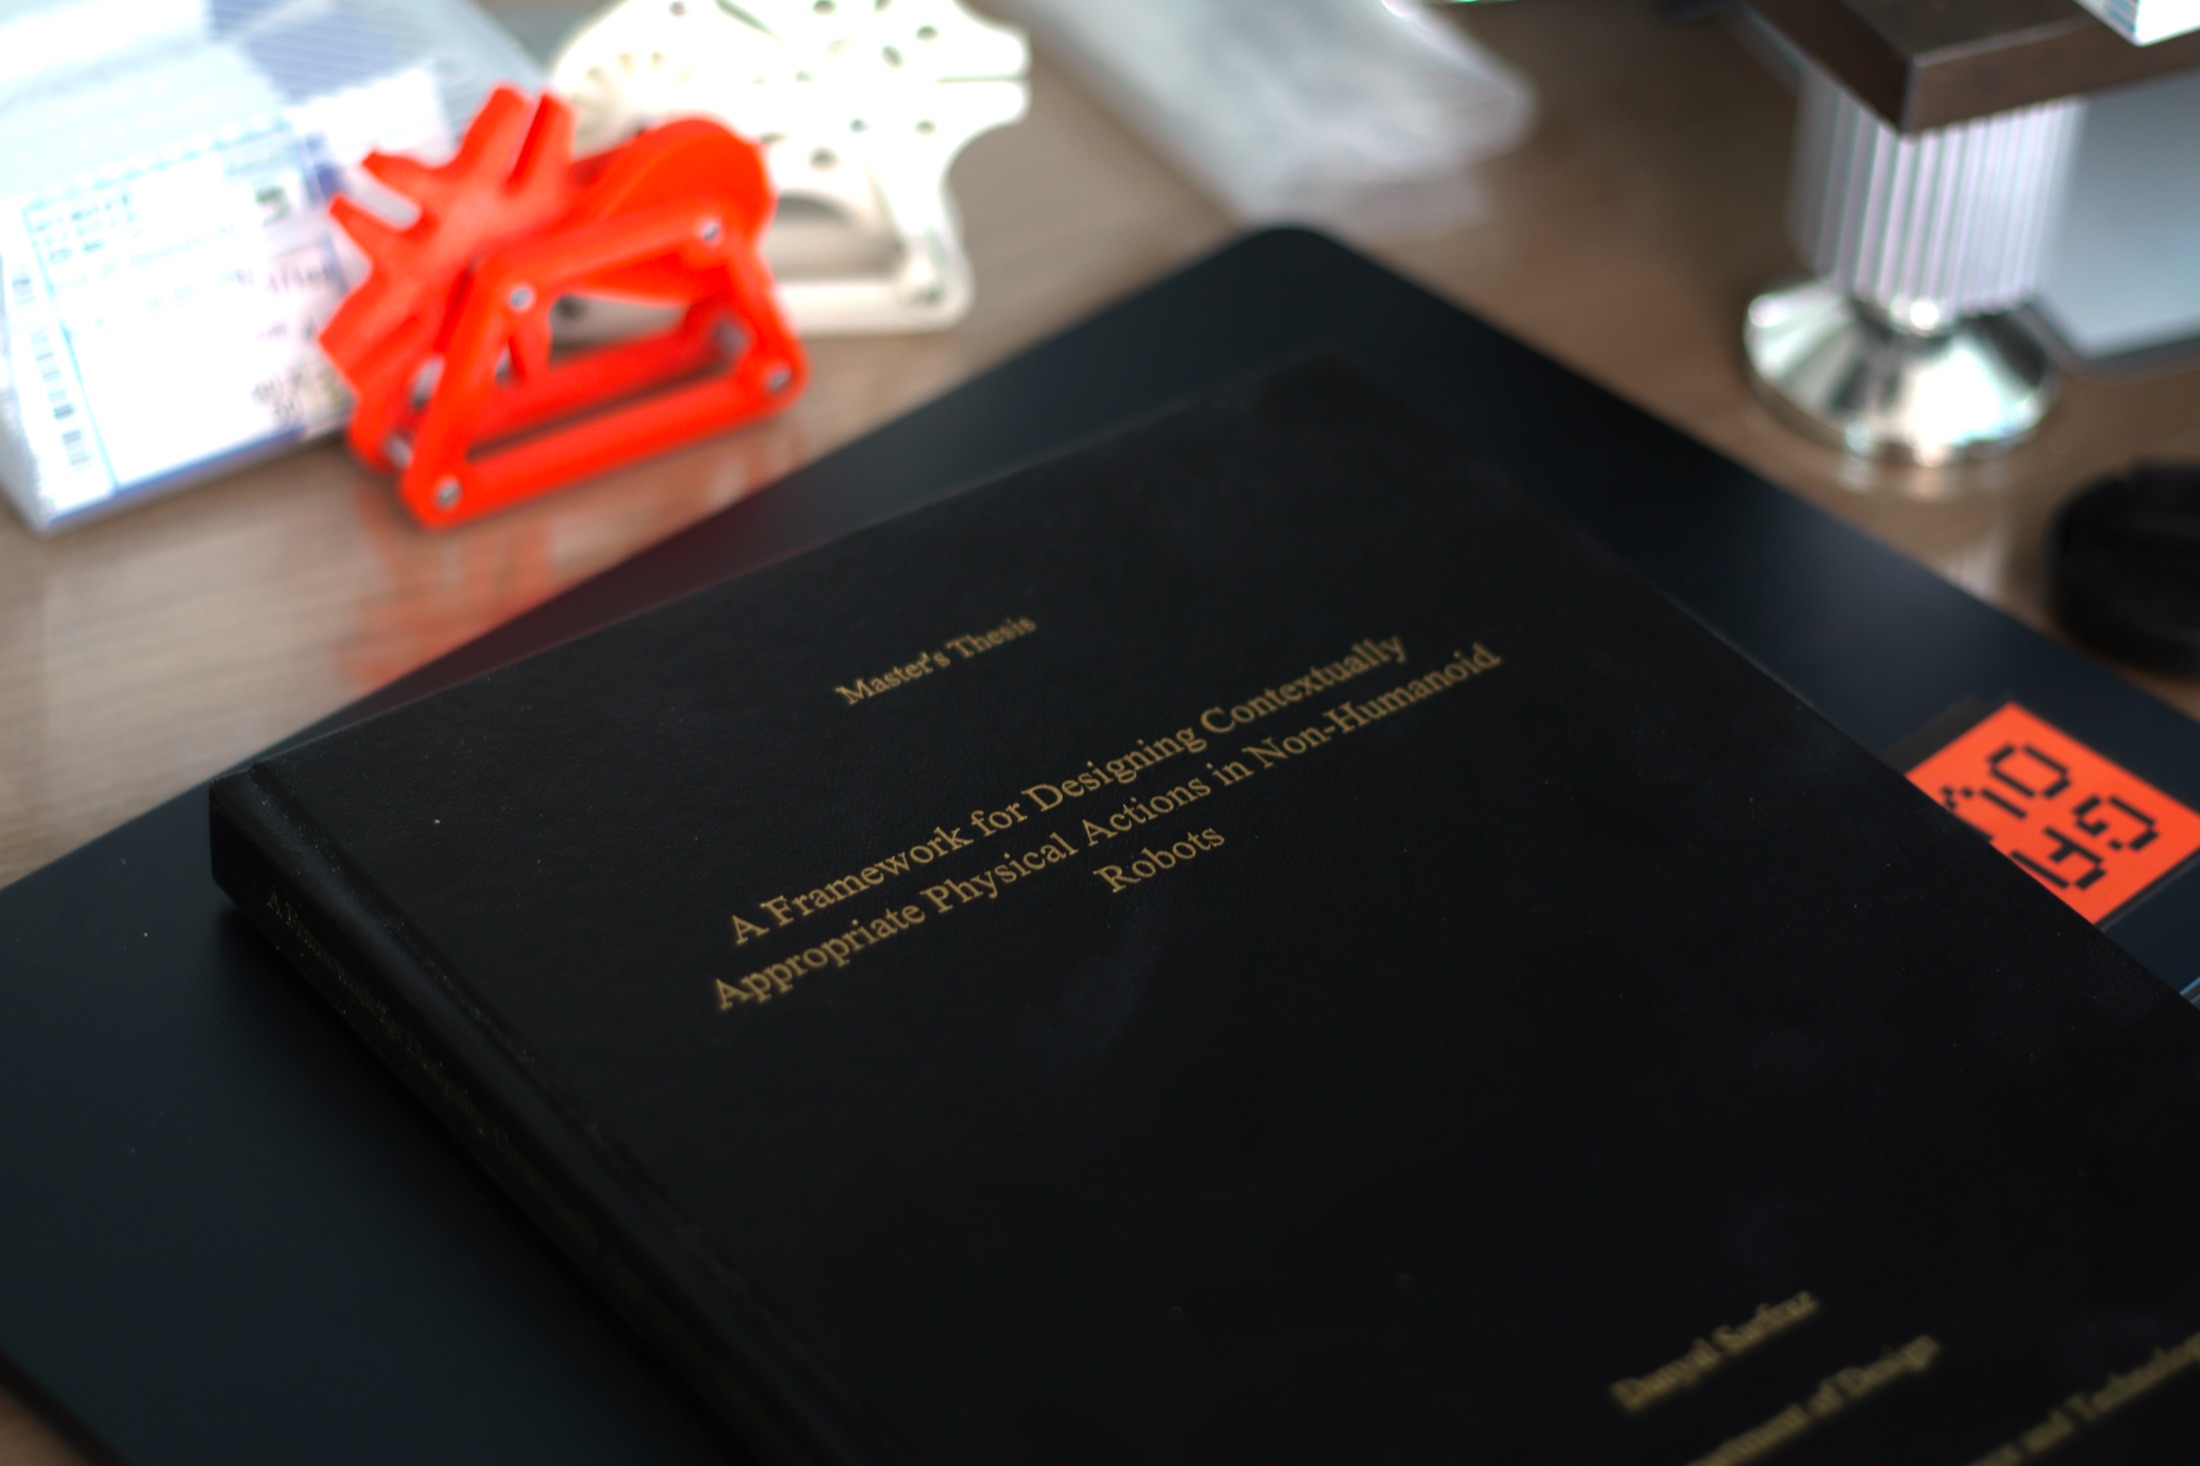
2025년 12월, 석사 논문 심사 통과. 로봇의 물리적 동작을 디자인하기 위한 프레임워크입니다. 이를 바탕으로 한 논문이 ACM CHI 2027에서 심사 중입니다.
-
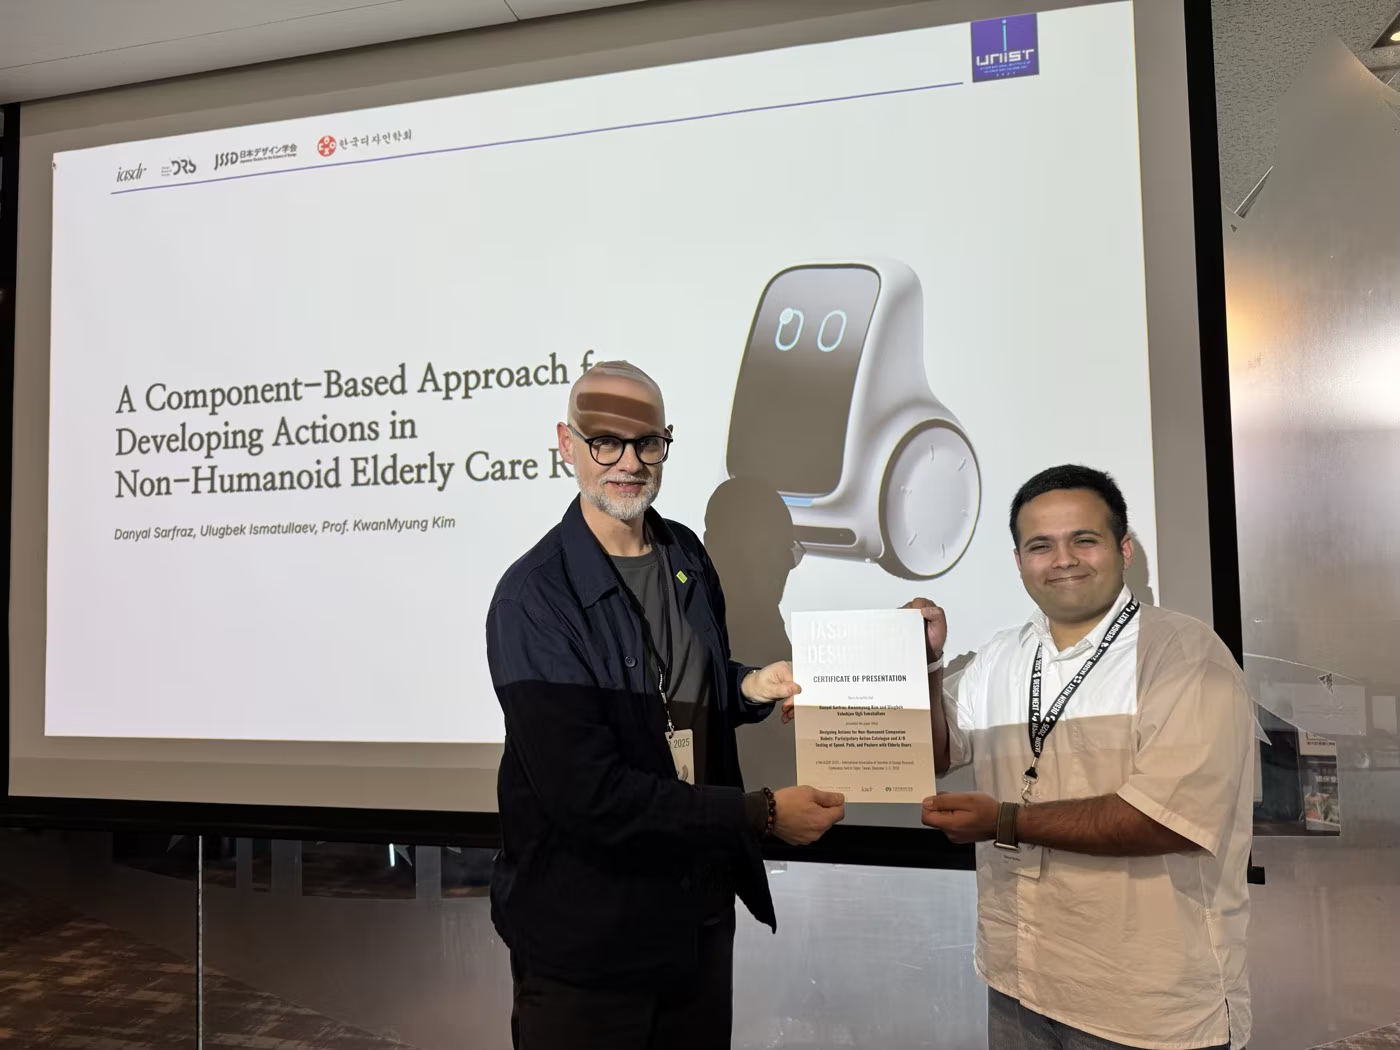
IASDR 2025, 타이베이. 로봇 동작에 관한 풀 페이퍼, AI 생성 영상에 관한 픽토리얼, 그리고 포스터 세션에서 만난 Don Norman.
-
2025년, 무대에 선 Lemmy. Innovation Award를 받은 CES 2025와 광주디자인비엔날레에서 데모를 선보였습니다.
-
Assessment of Multi-View Consistency in Automated Product Form Analysis
자세히 보기: Product form analysis논문@inproceedings{sarfraz2026multiview, author = {Sarfraz, Danyal and Kim, KwanMyung}, title = {Assessment of Multi-View Consistency in Automated Product Form Analysis}, booktitle = {Proceedings of the KSDS 2026 International Conference}, organization = {Korean Society of Design Science}, year = {2026} } -
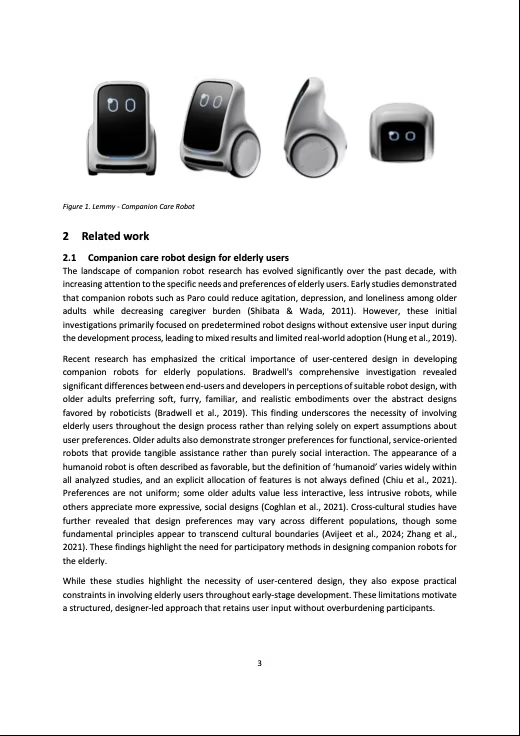
A Component-Based Approach for Developing Actions in Non-Humanoid Elderly Care Robots
자세히 보기: Lemmy논문@inproceedings{sarfraz2025component, author = {Sarfraz, Danyal and Ismatullaev, Ulugbek Vahobjon Ugli and Kim, KwanMyung}, title = {A Component-Based Approach for Developing Actions in Non-Humanoid Elderly Care Robots}, booktitle = {IASDR 2025: Design Next}, address = {Taipei, Taiwan}, publisher = {Design Research Society}, year = {2025}, doi = {10.21606/iasdr.2025.1139} } -
Synthetic Realities: Evaluating Human Ability to Distinguish AI-Generated Videos from Real Footage
자세히 보기: Synthetic Realities논문@inproceedings{sarfraz2025synthetic, author = {Sarfraz, Danyal and Karim, Raja Mubashar and Kim, KwanMyung}, title = {Synthetic Realities: Evaluating Human Ability to Distinguish AI-Generated Videos from Real Footage}, booktitle = {IASDR 2025: Design Next}, address = {Taipei, Taiwan}, publisher = {Design Research Society}, year = {2025}, doi = {10.21606/iasdr.2025.1050} } -
Developing a Hierarchically Structured Action Catalogue for an Elderly Care Robot through Participatory Design
자세히 보기: Lemmy논문@inproceedings{sarfraz2025catalogue, author = {Sarfraz, Danyal and Ismatullaev, Ulugbek and Kim, KwanMyung}, title = {Developing a Hierarchically Structured Action Catalogue for an Elderly Care Robot through Participatory Design}, booktitle = {Proceedings of the KSDS 2025 International Conference}, organization = {Korean Society of Design Science}, pages = {166--167}, year = {2025} }
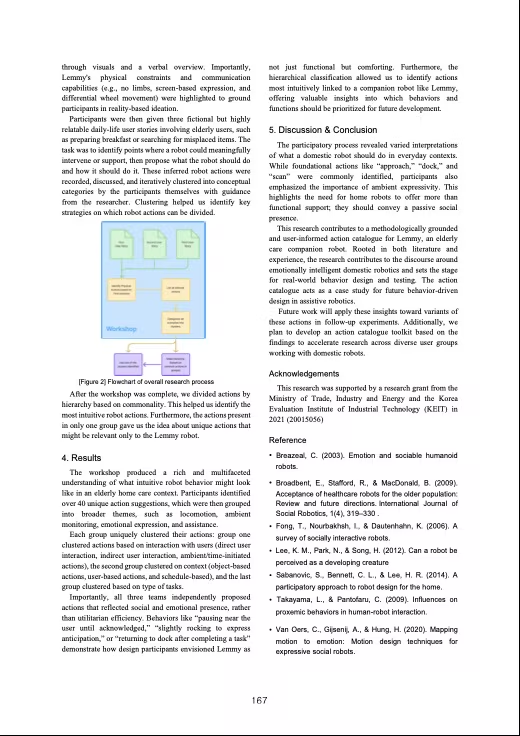
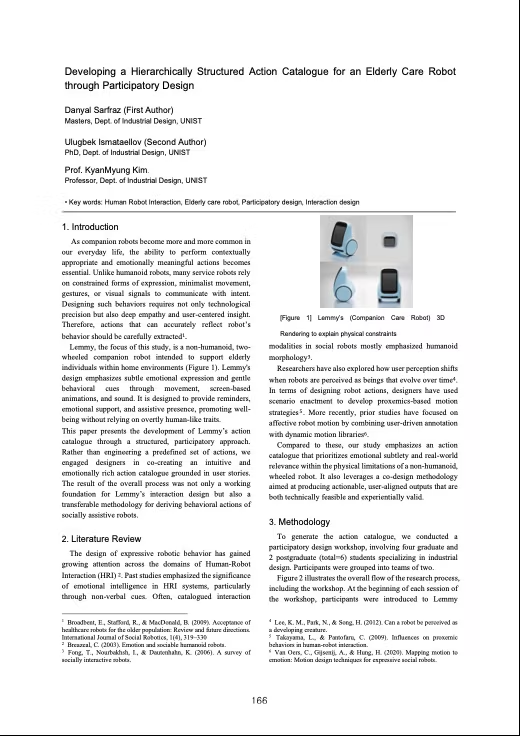
@mastersthesis{sarfraz2026framework,
  author = {Sarfraz, Danyal},
  title  = {A Framework for Designing Contextually Appropriate Physical Actions in Non-Humanoid Robots},
  school = {Ulsan National Institute of Science and Technology},
  type   = {{MSc} thesis},
  year   = {2026}
}
산학 협력 연구 프로젝트
2024년 2월부터 UNIST IID Lab에서 기업 및 정부 파트너와 함께 수행해 온 연구 과제입니다.
-
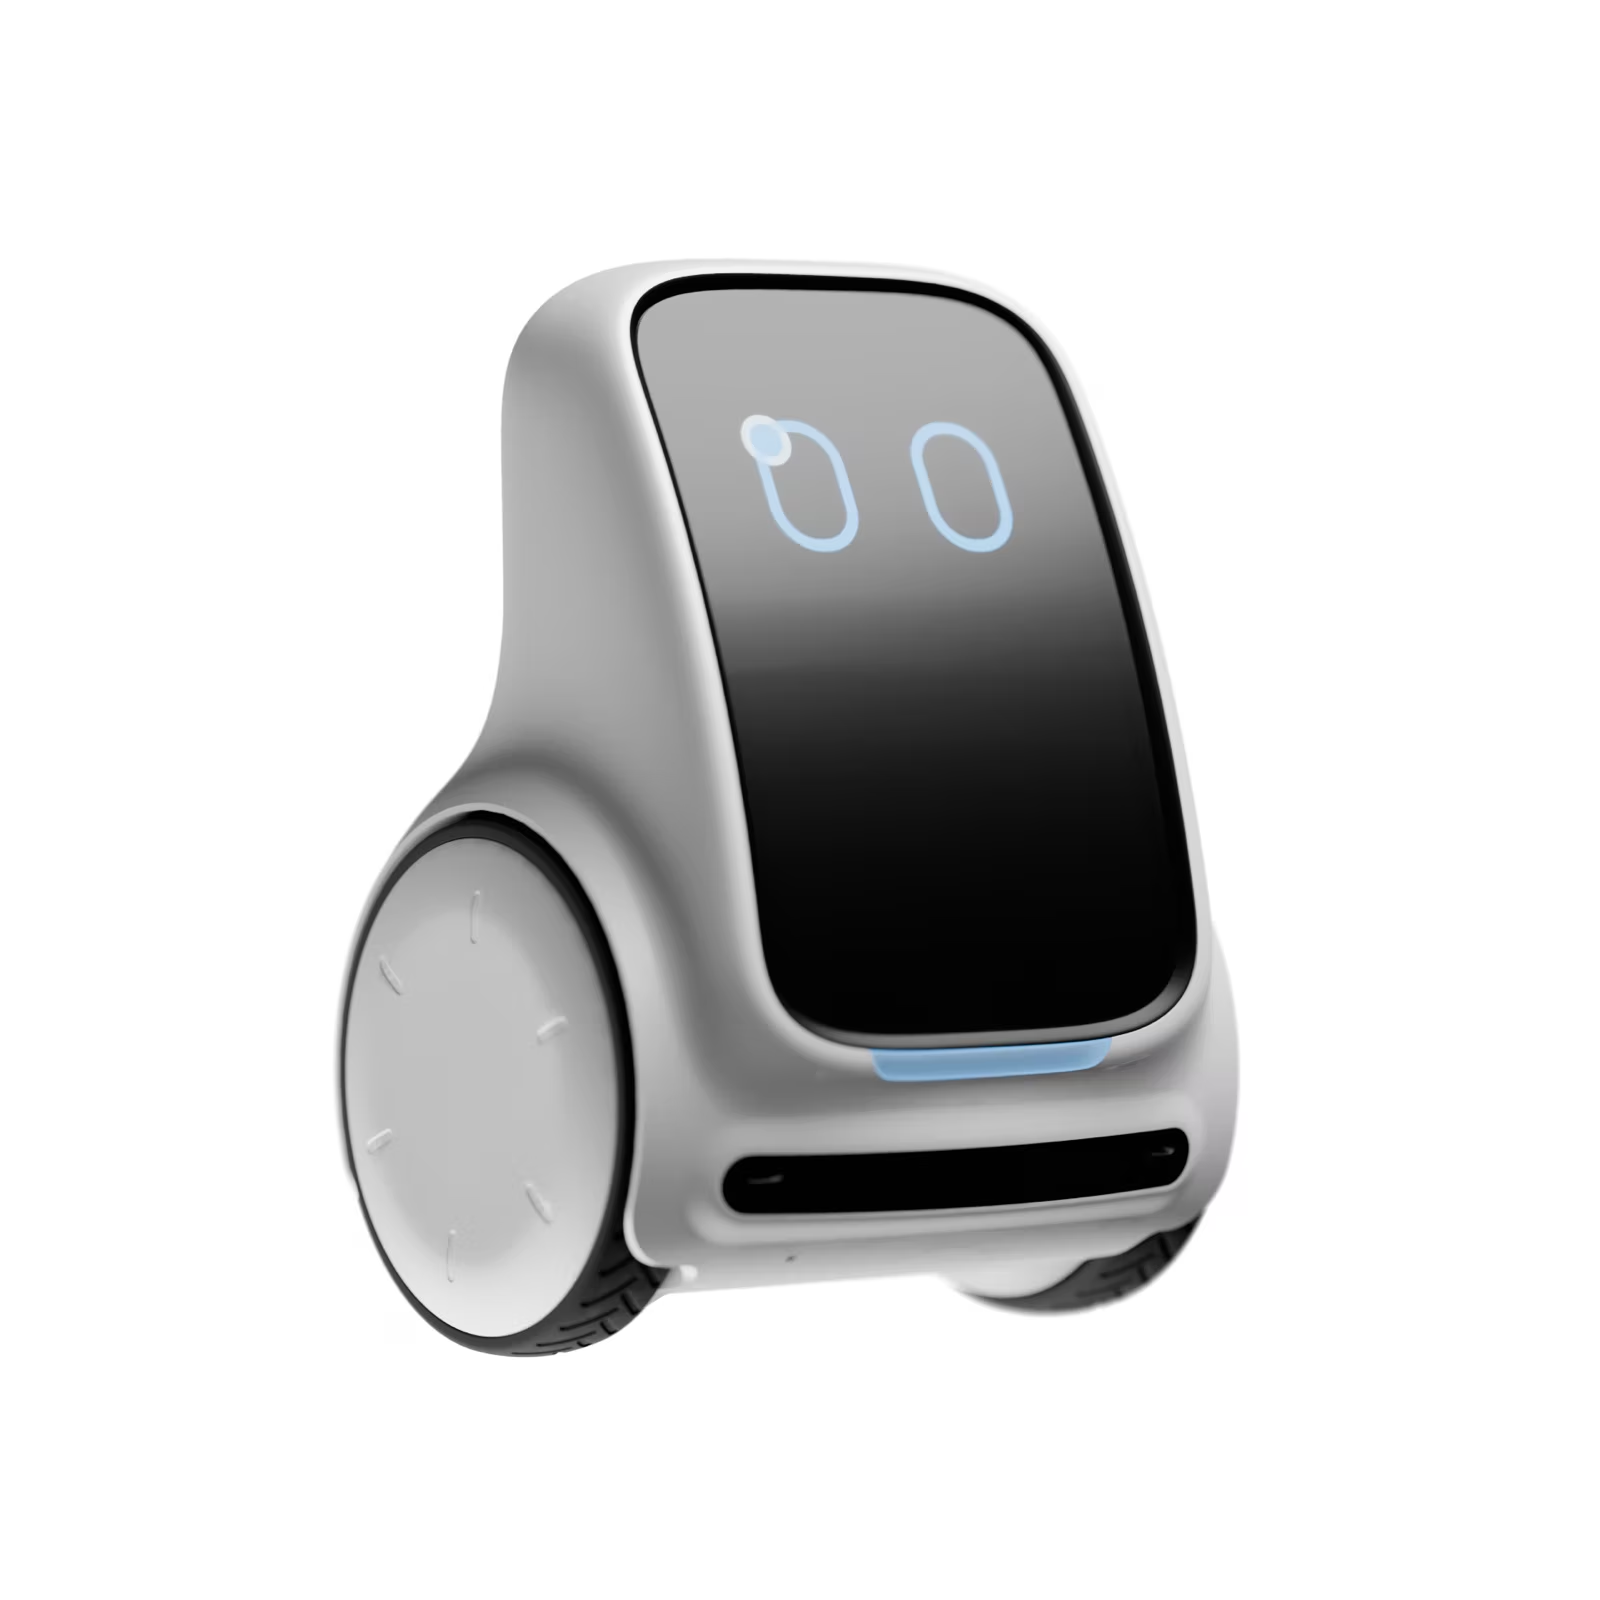
2024 – 2026 · 신성델타테크와 공동
고령자를 위한 지능형 맞춤 케어 제품-서비스 시스템
-

2025 – 현재 · Intensive, 고려대학교와 공동
디자인과 생산 간 충돌 요인의 예측과 최적화
-
2024 – 2026 · 대한민국 육군과 공동
민군 기술 협력: 전력 지원 체계 개발
담당 역할: 백팩 디자인, 무게 분산, 인간공학.
-
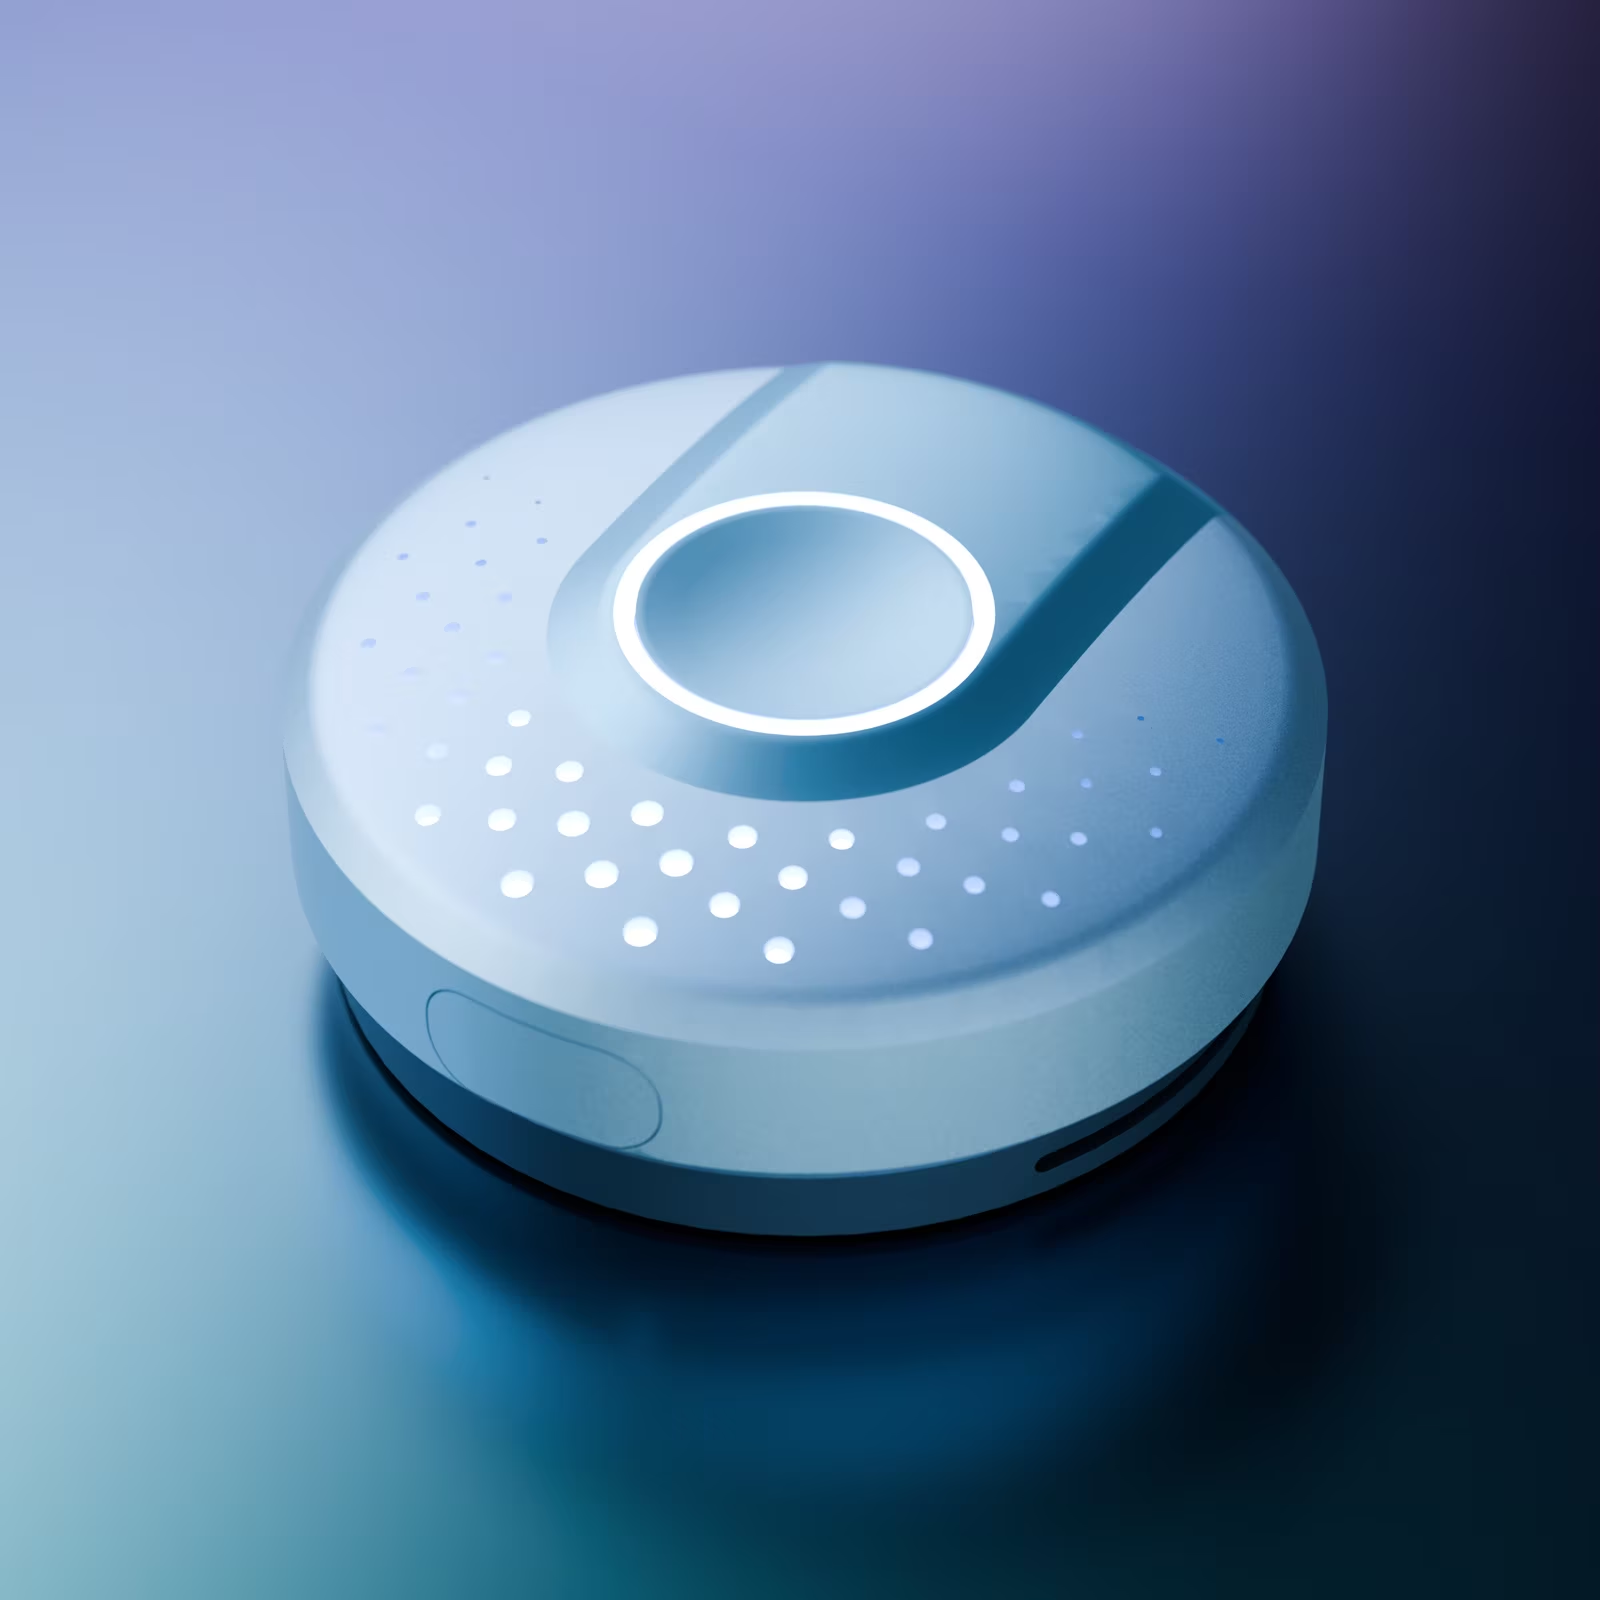
2024 · LG전자와 공동
상체 각도와 속도를 모니터링하는 센서 모듈
수상한 개인 프로젝트
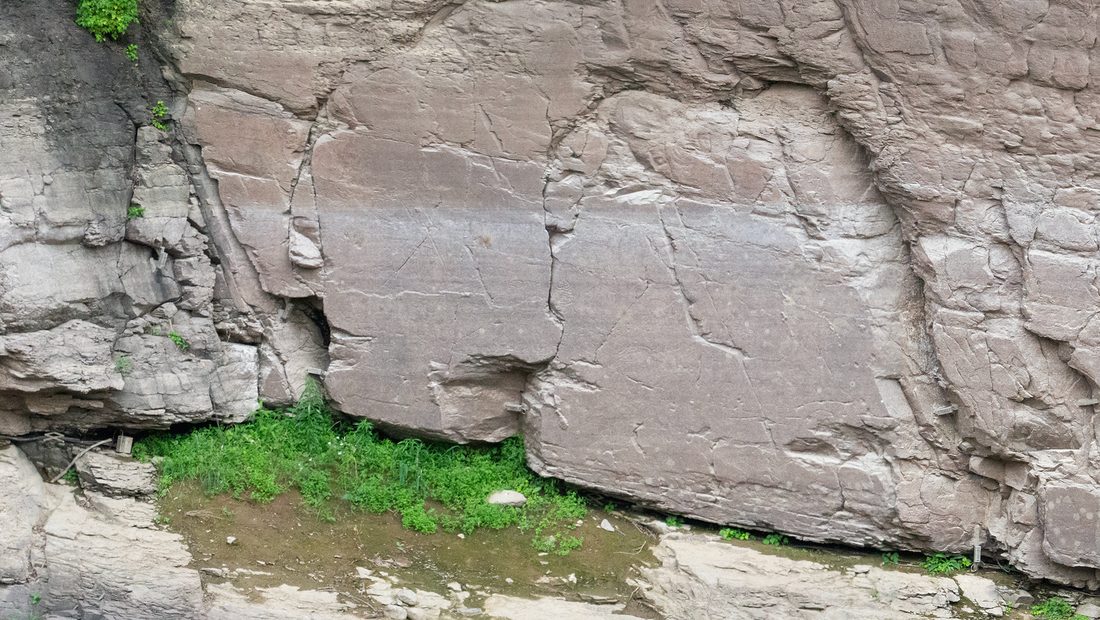
제3회 국가유산 디지털 콘텐츠 공모전 XR 부문 1위.
개인 프로젝트
HCI의 고전적인 문제를 집중적으로 다룬 세 가지 연구.
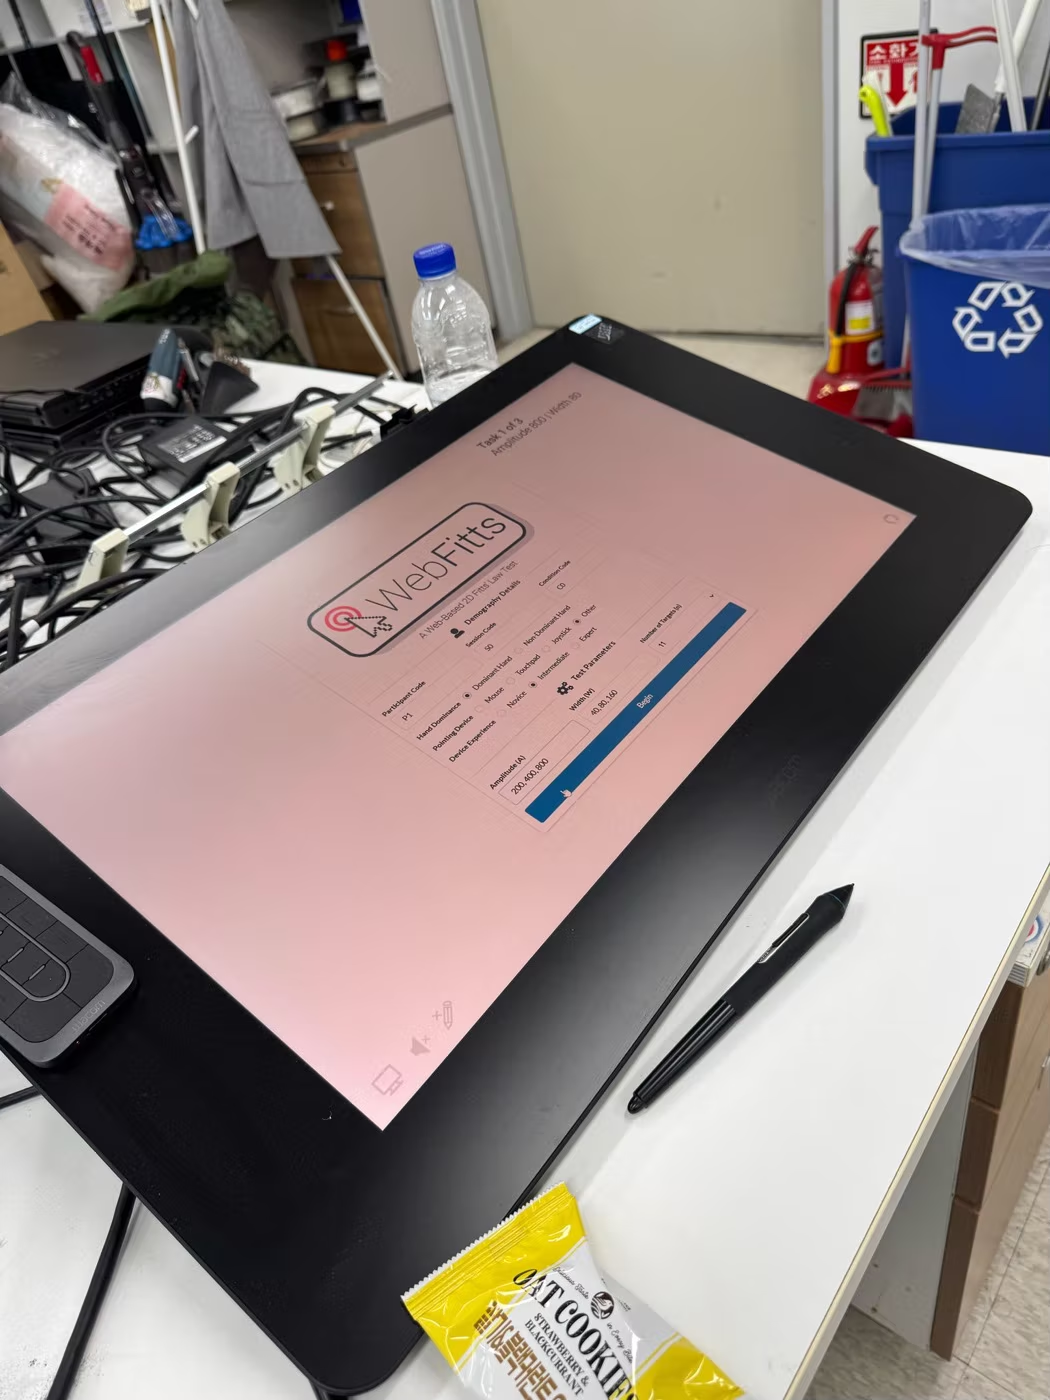
이 프로젝트들에는 아직 세상에 없던 도구가 필요했습니다. 그래서 직접 만들었습니다. 도구 보기